HIKROBOT MV-CE200-10GM — Area Scan Cameras
20 MP, Sony IMX183, GigE, Mono, 5.9 fps
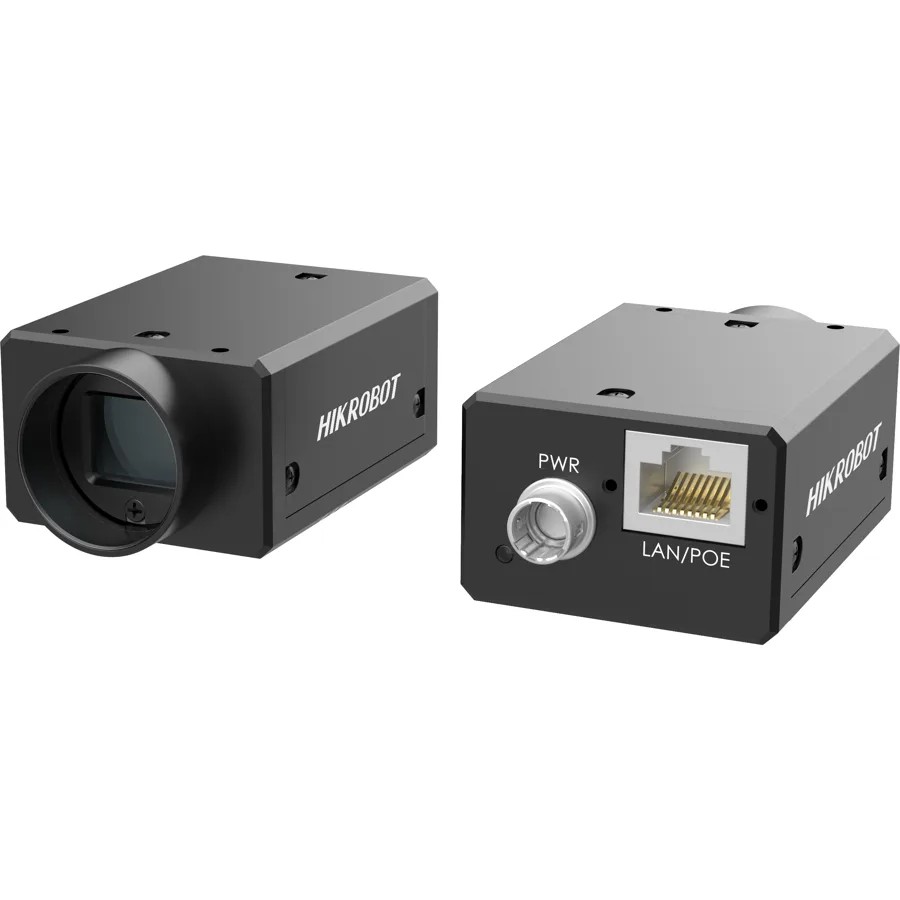
The MV-CE200-10GM is the GigE-interface sibling of the MV-CE200-10UM, built on the same 1″ Sony IMX183 sensor (2.4 μm pixels, 5472×3648, 41.5 dB SNR, 65.5 dB dynamic range). Transmitting over Gigabit Ethernet caps its max frame rate at 5.9 fps, well below the 19.2 fps of its USB3.0-interface counterpart on the same sensor, reflecting GigE’s narrower bandwidth. HIKROBOT lists this model under ‘Delisting Preparation’ as well.
The Gigabit Ethernet interface, compatible with Fast Ethernet, supports cable runs of up to 100 meters without a relay and up to 128 MB of local memory for burst transmission and retransmission — an advantage over USB3.0 in installations with long cable runs. It can be powered by 12 VDC external supply or PoE (typ. 3.1 W), retaining the same 6-pin Hirose I/O set (opto-isolated input/output plus a bi-directional line). GigE Vision V2.0 and GenICam compliance enable integration with the MVS client and third-party software.
Specifications
| CE Series — Economical Area Scan | |
|---|---|
| Model | MV-CE200-10GM |
| Performance | |
| Sensor type | CMOS, rolling shutter |
| Sensor model | Sony® IMX183 |
| Pixel size | 2.4 μm × 2.4 μm |
| Sensor size | 1″ |
| Resolution | 5472 × 3648 |
| Max. frame rate | 5.9 fps @ 5472 × 3648 |
| Dynamic range | 65.5 dB |
| SNR | 41.5 dB |
| Gain | 0 dB to 20 dB |
| Exposure time | 46 μs to 2 sec |
| Exposure mode | Off/Once/Continuous exposure mode, supports Global Reset |
| Mono | Mono |
| Pixel format | Mono 8/10/10p/12/12p |
| Binning | Supports 1 × 1, 2 × 2, 4 × 4 |
| Decimation | Not support |
| Reverse image | Supports horizontal reverse image output |
| Image buffer | 128 MB |
| Electrical feature | |
| Data interface | Gigabit Ethernet, compatible with Fast Ethernet |
| Digital I/O | 6-pin Hirose connector provides power and I/O, including opto-isolated input × 1 (Line 0), opto-isolated output × 1 (Line 1), bi-directional non-isolated I/O × 1 (Line 2). |
| Power supply | 12 VDC, supports PoE |
| Power consumption | Typ. 3.1 W@12 VDC |
| Mechanical | |
| Lens mount | C-mount |
| Dimension | 44 mm × 29 mm × 59 mm (1.7″ × 1.1″ × 2.3″) |
| Weight | Approx. 100 g (0.22 lb.) |
| Ingress protection | IP30 (under proper lens installation and wiring) |
| Temperature | Working temperature: 0 °C to 50 °C (32 °F to 122 °F) Storage temperature: –30 °C to 70 °C (–22 °F to 158 °F) |
| Humidity | 20% RH to 80% RH (no condensation) |
| General | |
| Client software | MVS or third-party software meeting with GigE Vision Protocol |
| Operating system | 32/64-bit Windows 7/10, 32/64-bit Linux |
| Compatibility | GigE Vision V2.0, GenlCam |
| Certification | CE, RoHS, KC |
| HIKROBOT part no. | SM000025504 |
| Status | Being discontinued |
Key features
- Adopts GigE interface and max. transmission distance of 100 meters without relay.
- Up to 128 MB local memory for burst transmission and retransmission.
- Supports auto exposure control, LUT, Gamma correction, etc.
- Supports hardware trigger, software trigger, etc.
- Compatible with GigE Vision Protocol V2.0, GenICam Standard, and third-party software based on these protocol and standard.
Where it is used
The GigE interface and its 100-meter cable range are useful in large facility lines where the camera sits far from the control cabinet, or in installations where multiple cameras are managed over a network; the 20 MP resolution captures fine detail on large parts and panels. The 5.9 fps rate suits triggered, high-resolution single-frame capture at PoE-powered fixed stations rather than high-speed line tracking.
Suitability depends on working distance, field of view, target characteristics and positioning. Selection is assessed on a per-project basis.
Is this camera right for your application?
Let us determine resolution, interface, lens and illumination together, based on your application. FST is HIKROBOT’s distributor in Türkiye; product selection, commissioning and after-sales support all come from one source.
The data herein may vary based on the environment, objects and other various factors, and HIKROBOT shall not assume the consequences arising therefrom.
Source: HIKROBOT product data